
Projects
Projects
A glimpse into my hands-on work—robotics systems, algorithms, and autonomous navigation implementations.
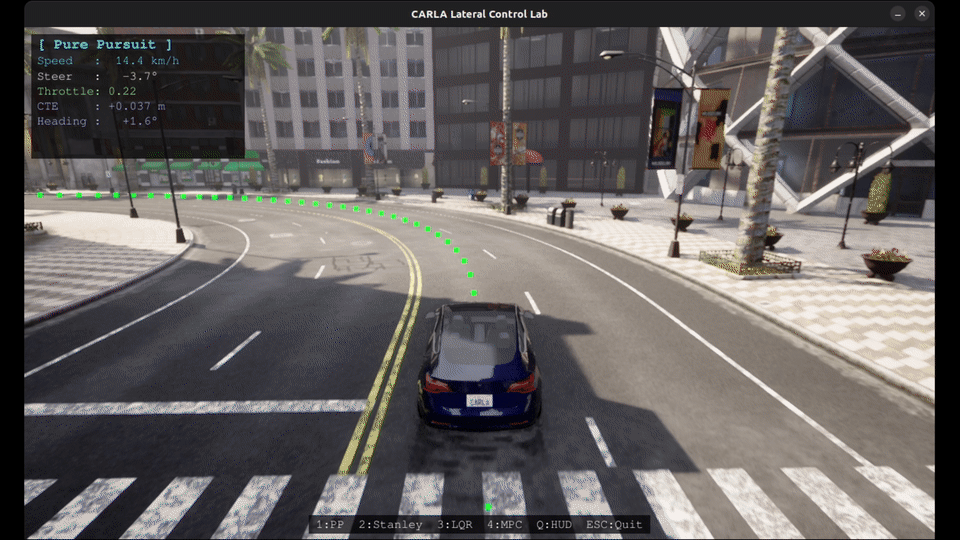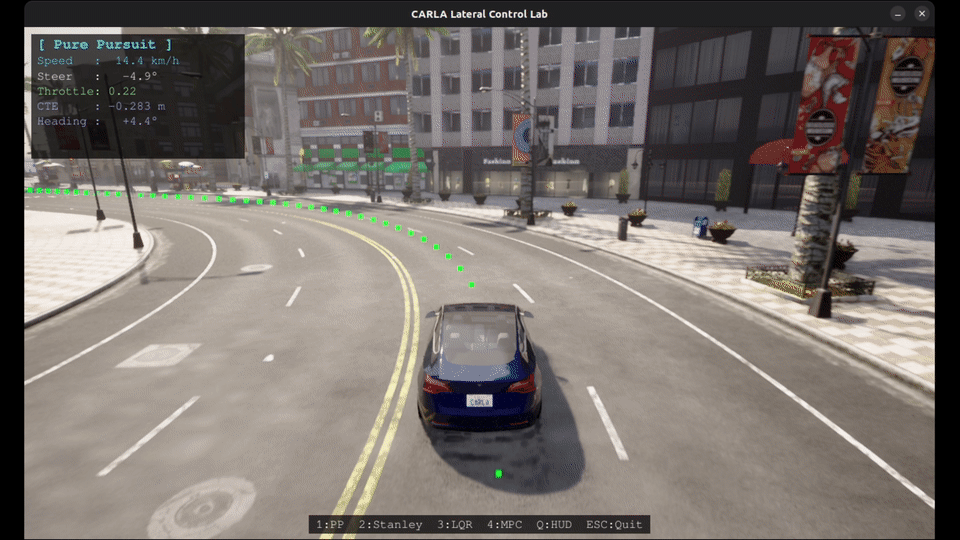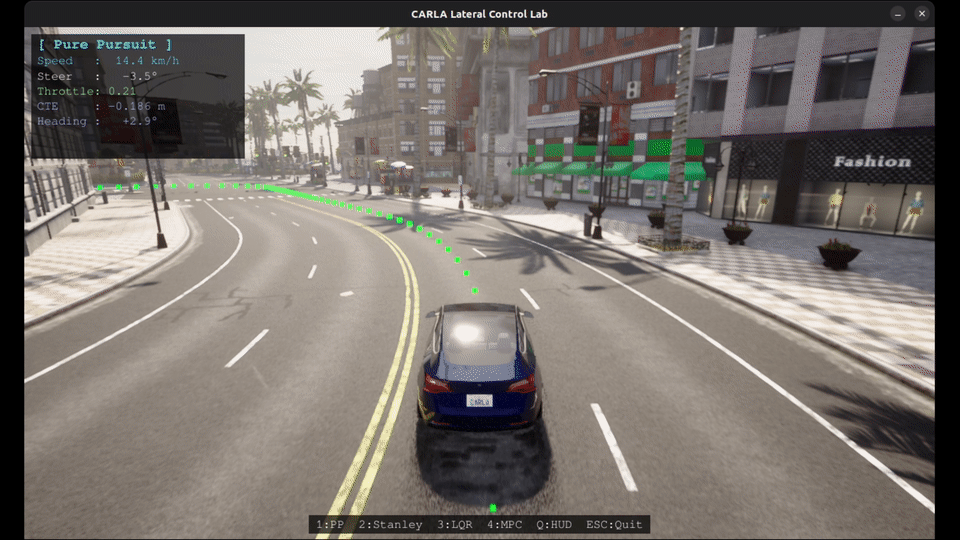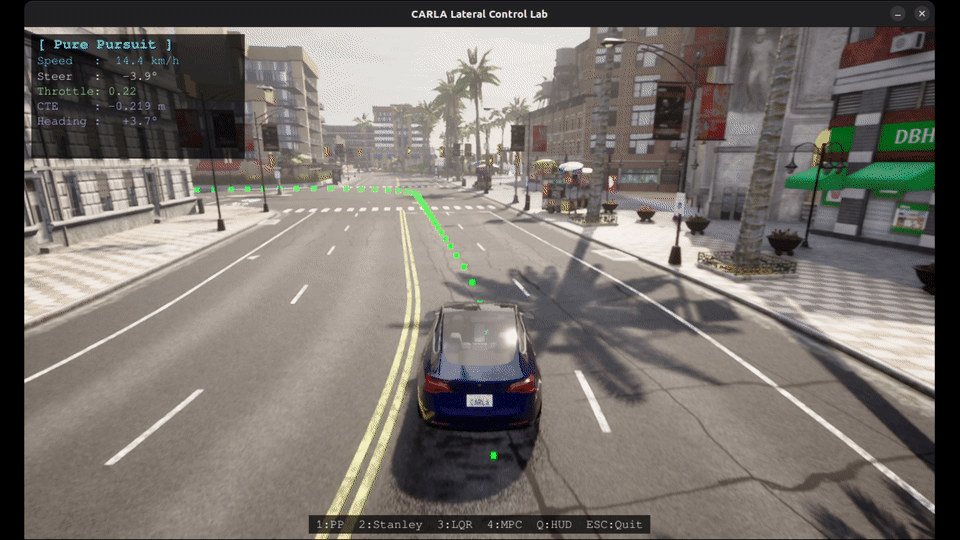
CARLA Steer Lab (Lateral Control Benchmarking)
Jun 2026Benchmarking Pure Pursuit, Stanley, LQR, and MPC lateral control algorithms in CARLA with real vehicle physics. Includes a live interactive runner with pygame HUD and full telemetry analysis across four track types.
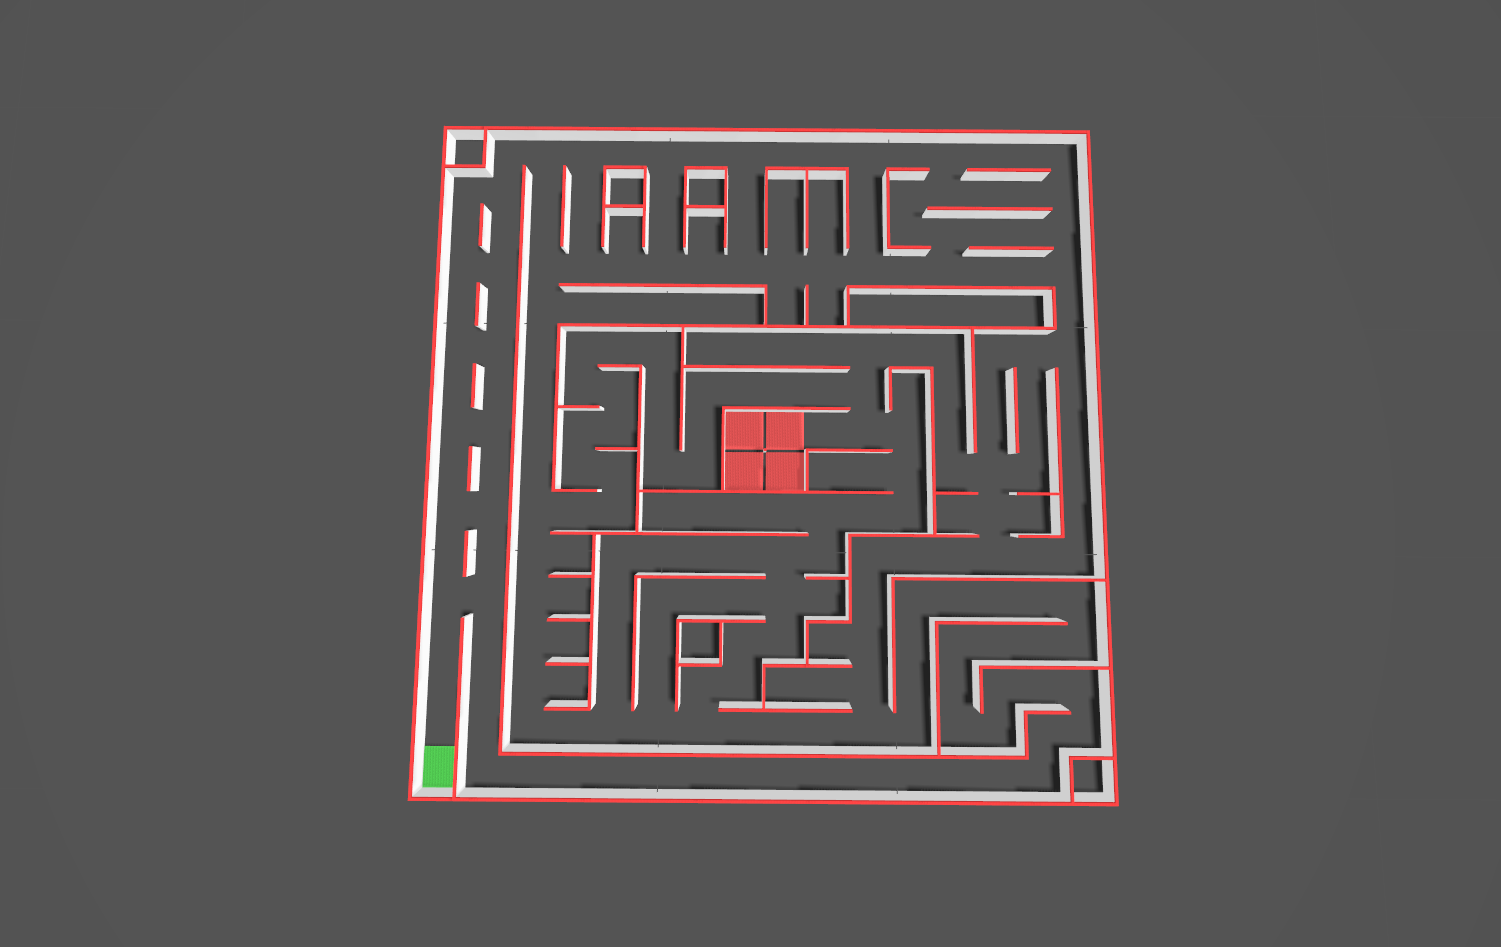
MazeGen IGN Gazebo (Dynamic Maze Generation Plugin)
May 2026Gazebo Ignition Fortress world-system plugin for spawning MicroMouse-format maze environments. Reads maze text files and generates physics-based simulation with walls, posts, and start/goal markers.
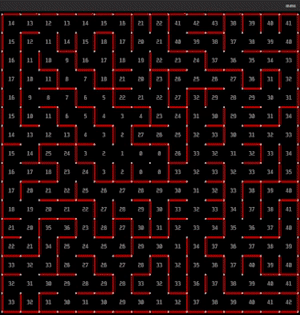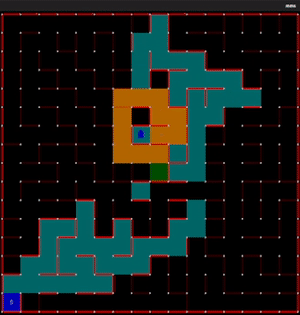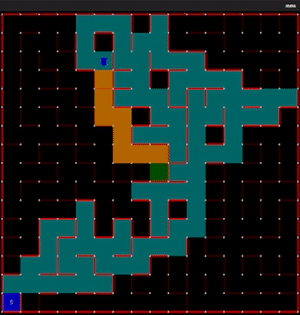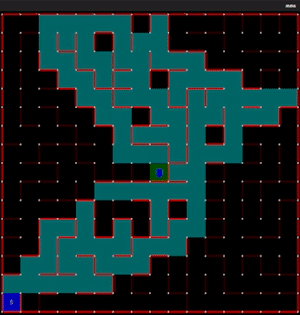
MicroMouse Goal Navigation
Oct 2024Multiple maze-solving algorithms (Dijkstra, A*, BFS, DFS) optimized for MicroMouse competition with real-time navigation and incremental replanning.
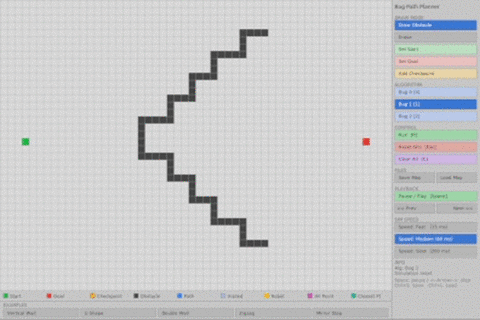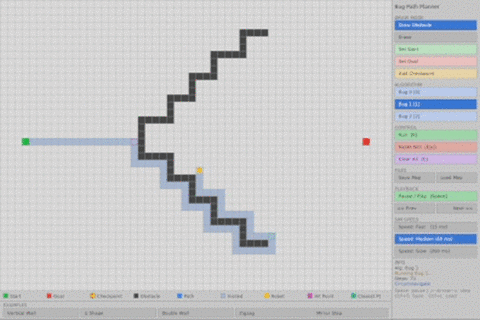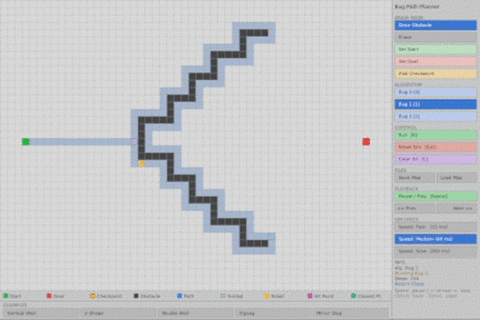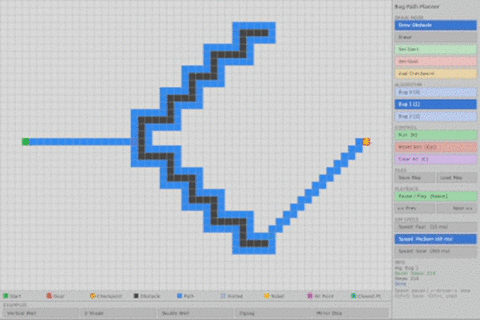
Bug Path Planner — Interactive Navigation Algorithm Visualizer
Sep 2024C++ implementation of reactive navigation algorithms (Bug0, Bug1, Bug2) with SDL2 visualization. Features real-time animation, step-through debugging, interactive map editor, and algorithm comparison.
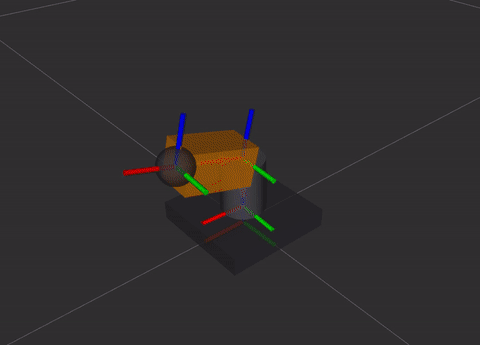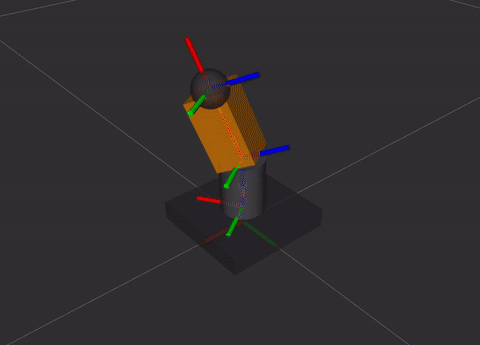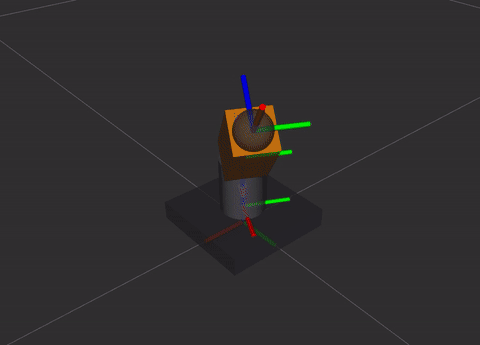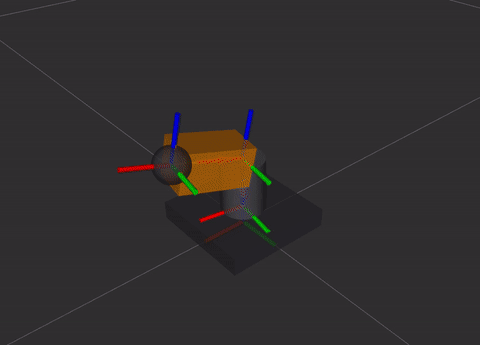
URDFGenPy — Programmatic URDF Generation
Aug 2024Python library for programmatically generating URDF and Xacro robot descriptions with type-safe APIs for parametric robot design.
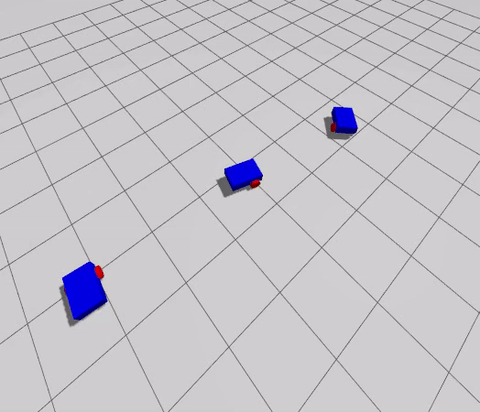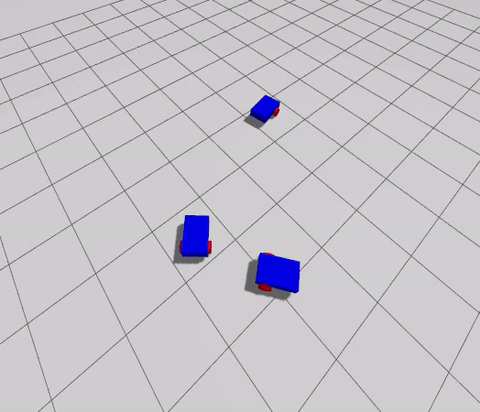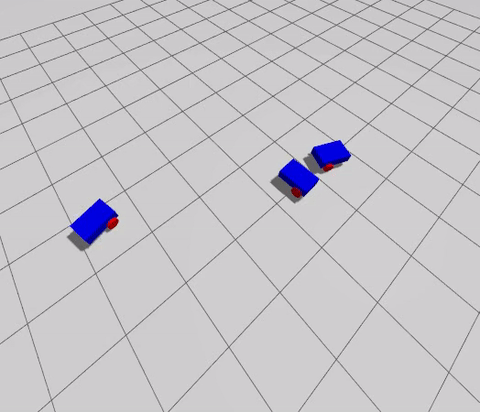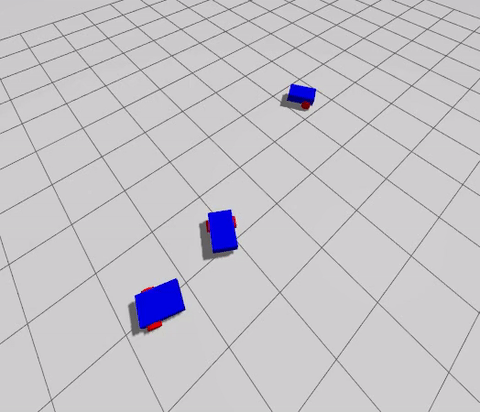
Project Zoomlet — Multi-Robot Differential Drive Simulation
Jul 2024Complete ROS 2 mobile robot stack with URDF/Xacro modeling, physics-tuned Gazebo integration, and multi-robot coordination with joystick teleoperation.
MoveIt Application — Robot Arm Motion Planning
Jun 2024MoveIt2 application for robotic arm motion planning with RRT planners, collision avoidance, trajectory optimization, and IK solvers.
Perception-Driven Autonomous Navigation
May 2024Camera-only navigation system on TurtleBot4 using ArUco markers, YOLOv8n stop sign detection, and obstacle avoidance with real-world hardware validation.
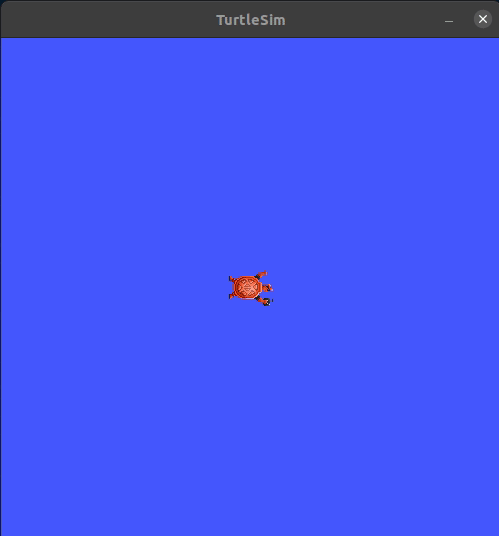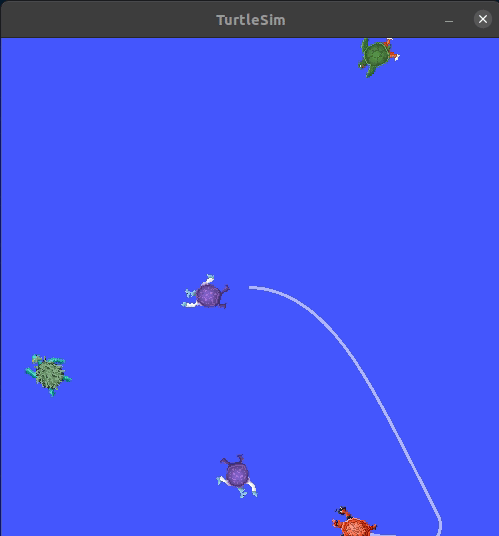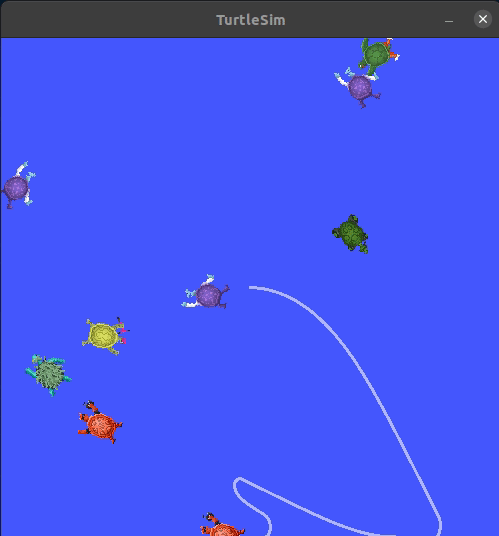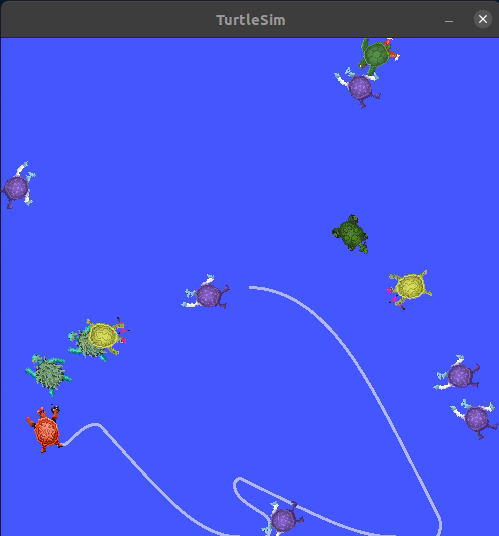
Catch-a-Turtle — ROS 2 Turtlesim Chase System
Mar 2024ROS 2 application with two-node architecture for autonomous turtle chasing. Spawner creates turtles at random positions; controller identifies nearest target and pursues autonomously.
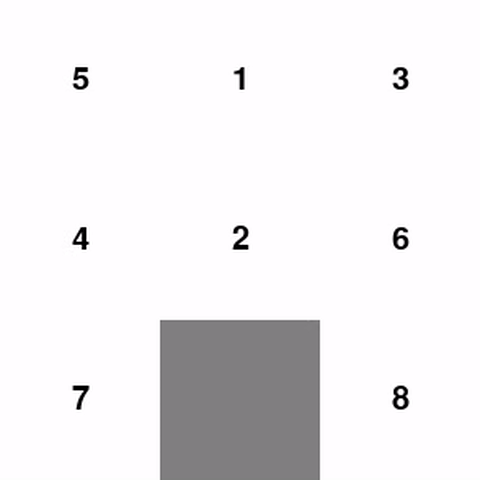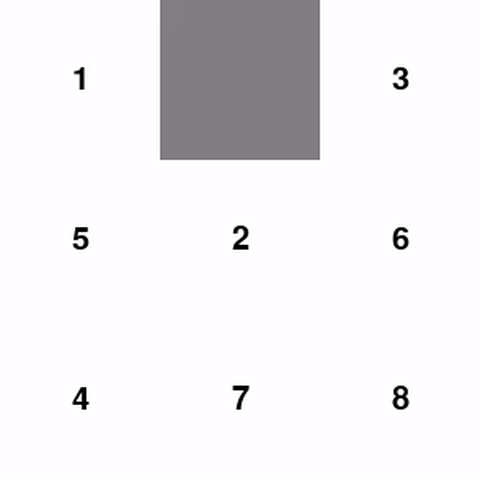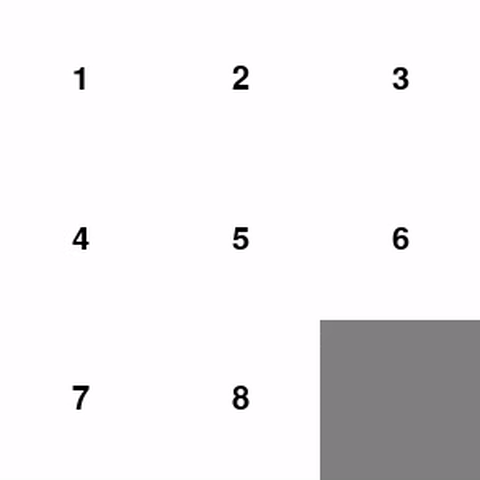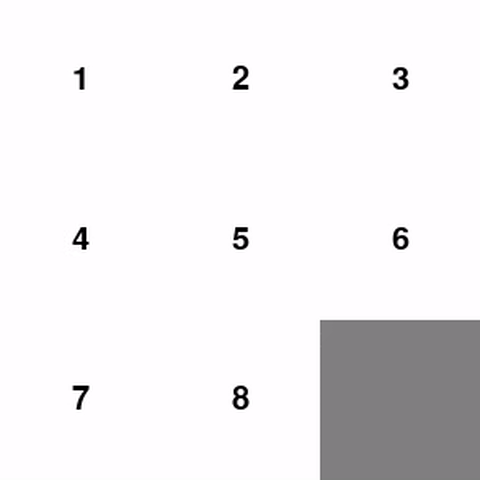
8-Puzzle Solver — A* Search Implementation
Feb 2024C++ implementation of the classic 8-puzzle problem using A* search algorithm with Manhattan distance heuristic. Includes visualization and performance metrics.
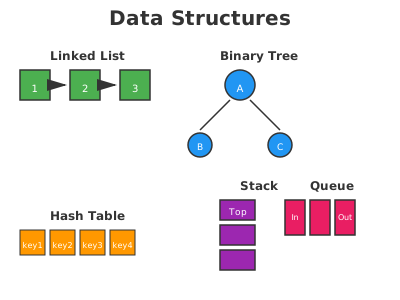
Data Structures in C++ — From Scratch Implementation
Jan 2024Complete implementations of fundamental data structures (linked lists, AVL/Red-Black trees, heaps, graphs, hash tables) built from scratch with complexity analysis.
No projects match this tag.