
Overview
Gazebo Ignition plugin for dynamically spawning MicroMouse-format maze environments with accurate physics simulation following official competition rules.
Features
- Maze File Support: Reads micromouseonline-format maze text files
- Physics Integration: Spawns walls, posts, and floor tiles in Gazebo Ignition
- Official Compliance: 16×16 grid, 180mm cells, 50mm walls, 12mm thickness
- Start/Goal Markers: Green start cells, red goal cells with floor tiles
- Customizable Geometry: Wall height, thickness, post size configurable
Technical Specifications
- Framework: Gazebo Ignition Fortress (gz-sim 6)
- Plugin Type: World System (ISystemConfigure)
- Cell Size: 180 mm (MicroMouse standard)
- Wall Properties: 12mm thick × 50mm tall, white sides, red tops
- Posts: 12×12×50 mm at grid intersections
- Language: C++
Maze File Format
Plain text format with:
o= grid intersection post---= horizontal wall|= vertical wallS= start cell (green)G= goal cell (red)
Example:
o---o   o
| S | G |
o---o---o
Gallery
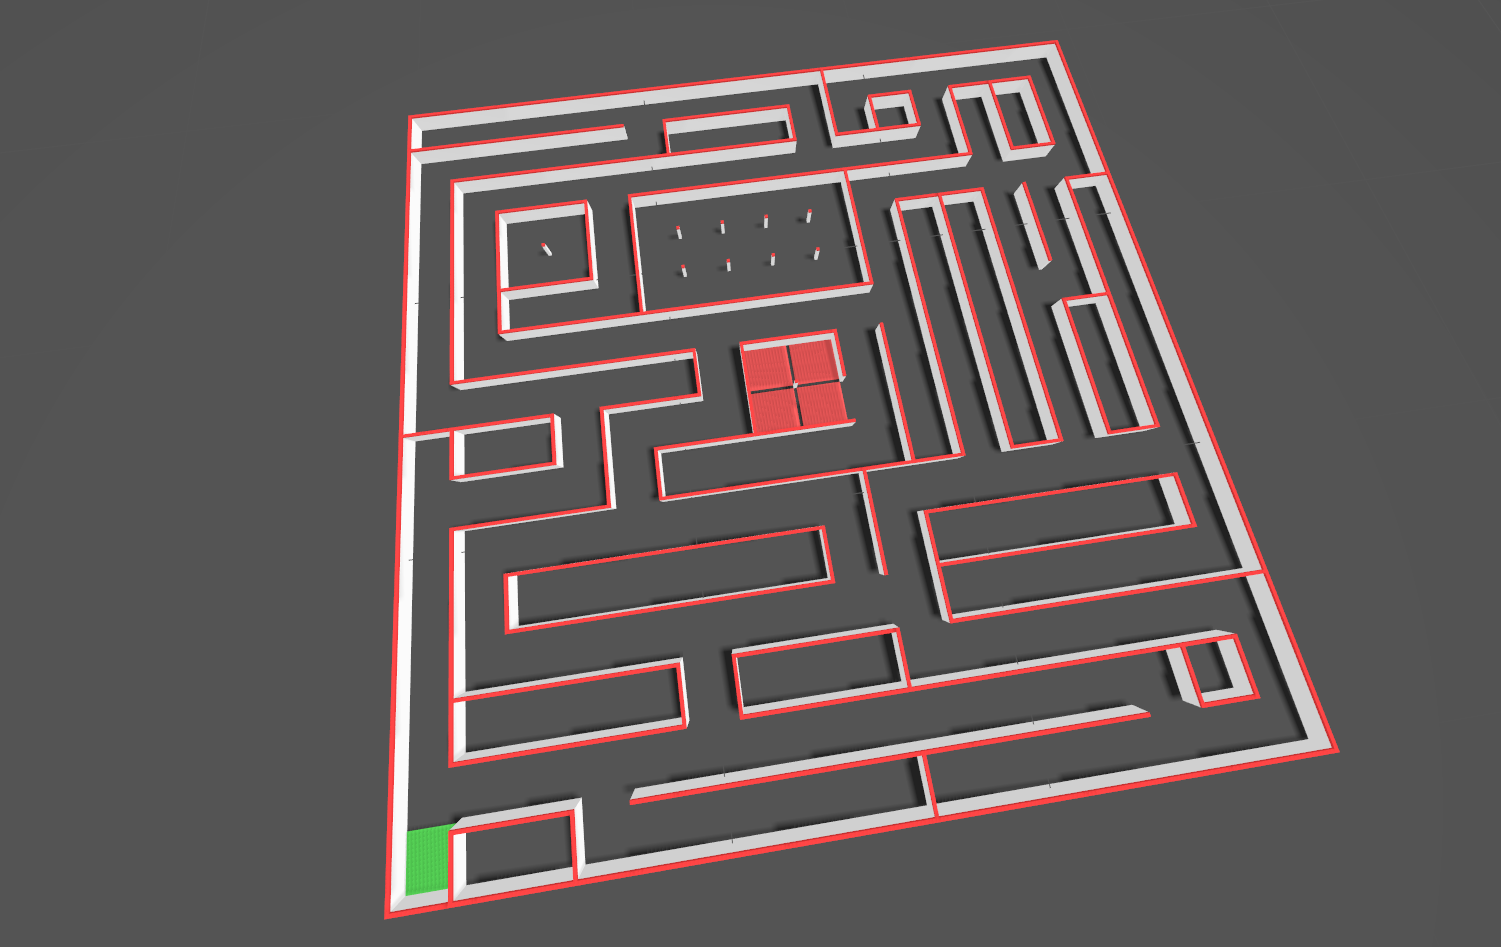
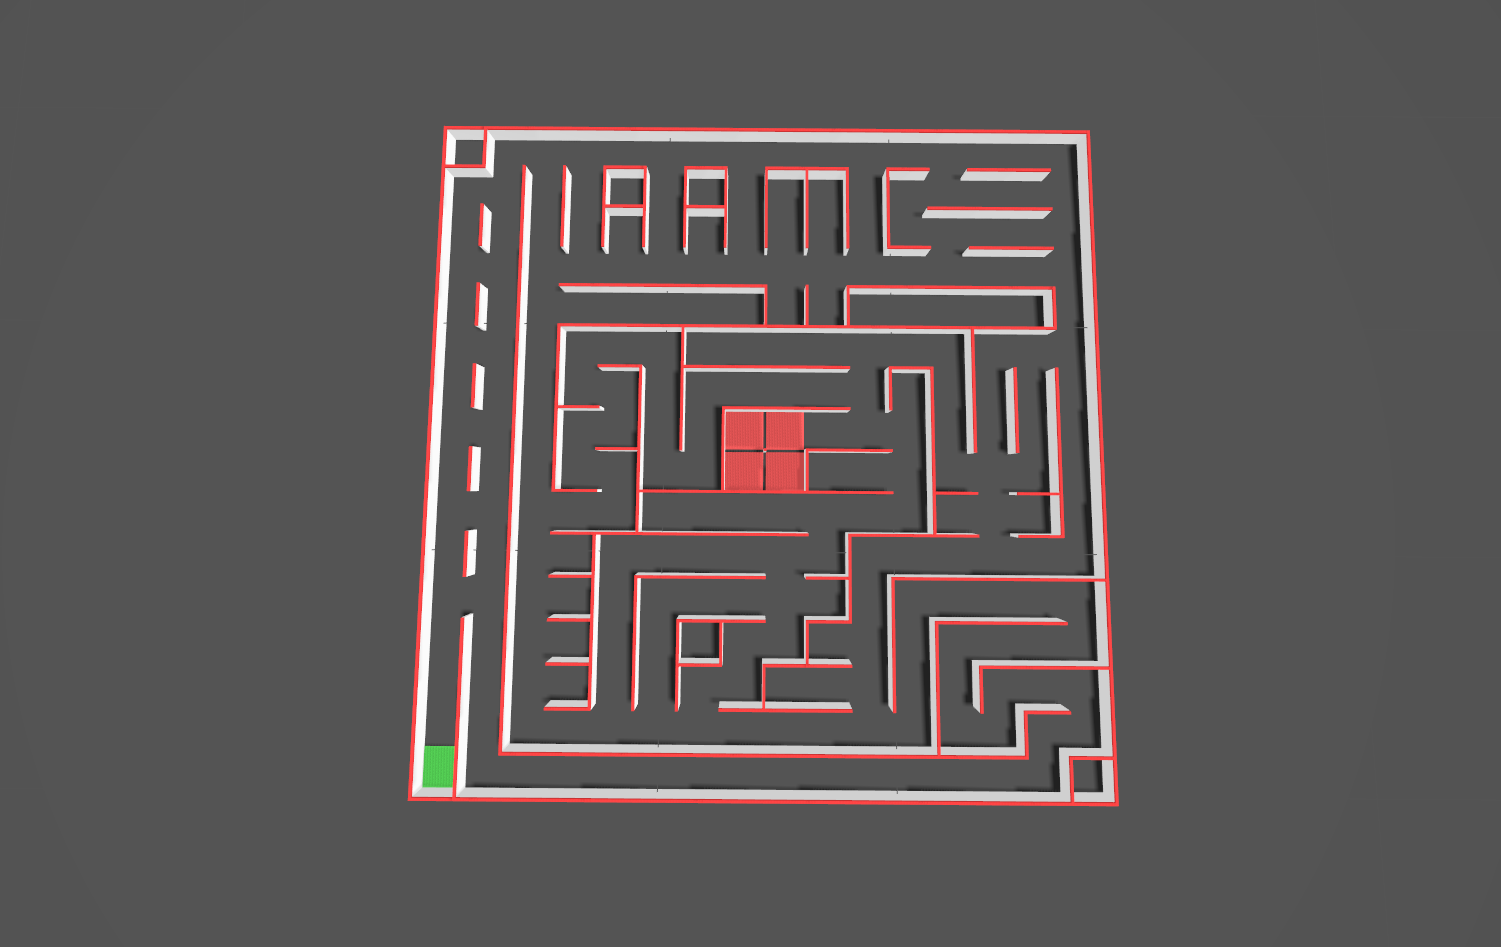
Getting Started
git clone https://github.com/svaibhav101/mazegen_ign_gazebo.git
cd mazegen_ign_gazebo && mkdir build
cmake -S . -B build && cmake --build build -j
ctest --test-dir build  # Run parser tests
Use Cases
- MicroMouse competition simulation
- Robot navigation algorithm testing
- Benchmark scenario generation
- Educational robotics projects