
Home
Vaibhav Shende
Robotics & ML Engineer
Combining perception, planning, and learning to create robots that understand and navigate complex real-world environments.
Recent Writing
View all →Featured Projects
View all →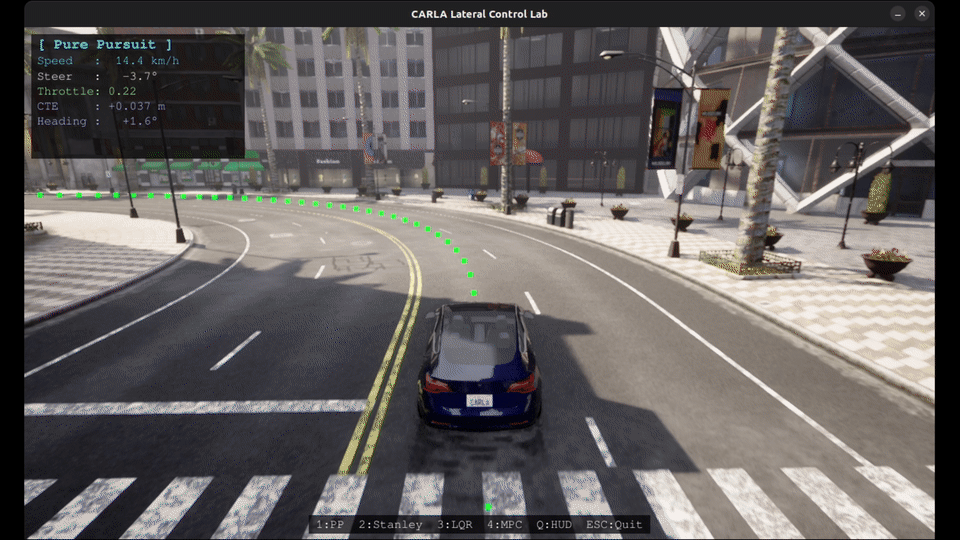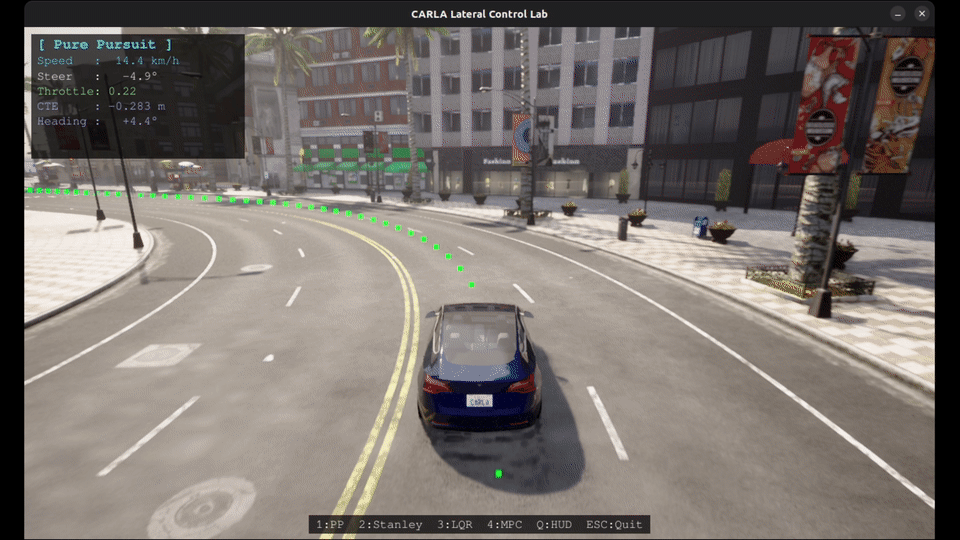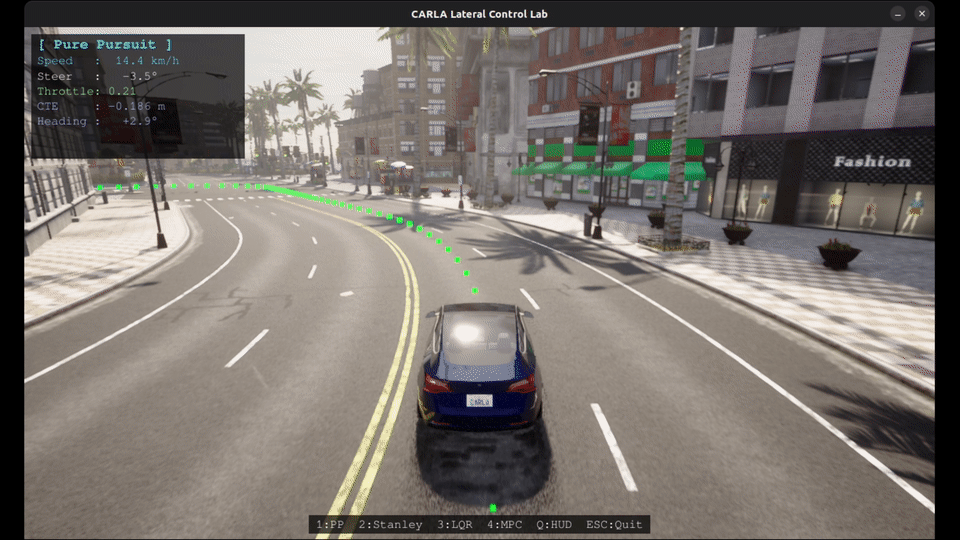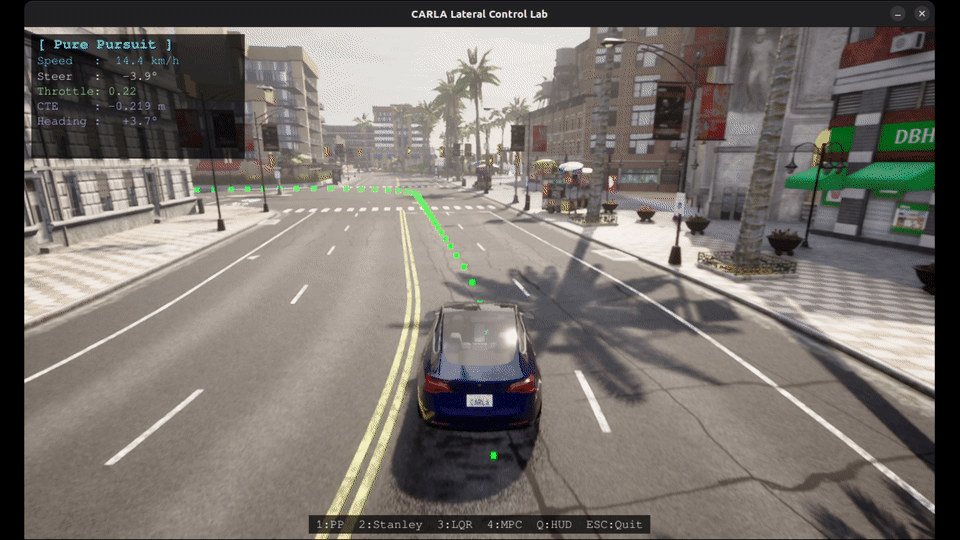
CARLA Steer Lab — Lateral Control Benchmarking
Benchmarking Pure Pursuit, Stanley, LQR, and MPC lateral control in CARLA with real vehicle physics, live pygame HUD, and full telemetry analysis across four track types.
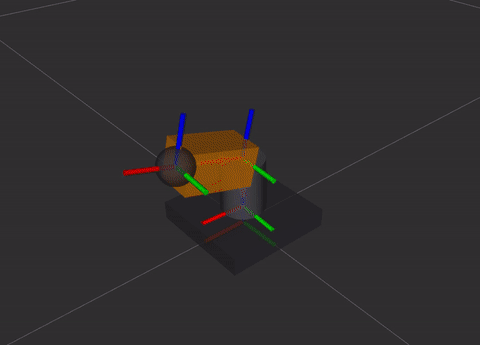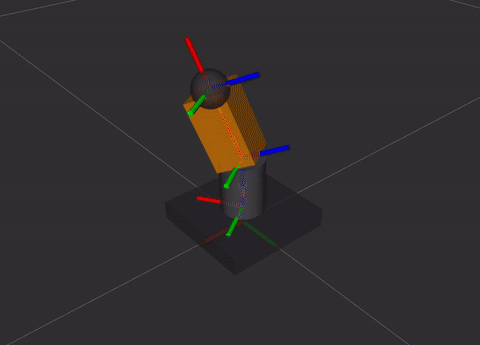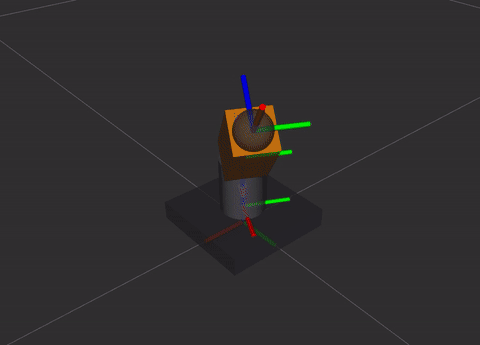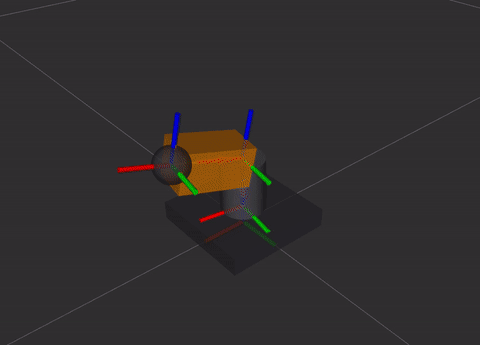
URDFGenPy : Programmatic URDF Generation
Python library for programmatically generating URDF and Xacro robot descriptions with type-safe APIs for parametric robot design.
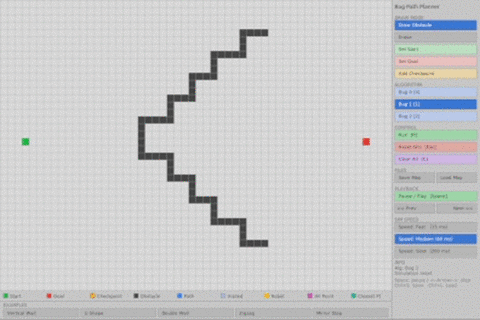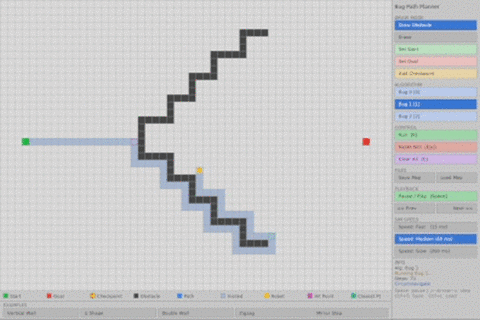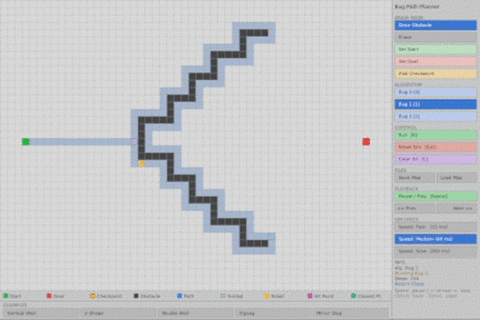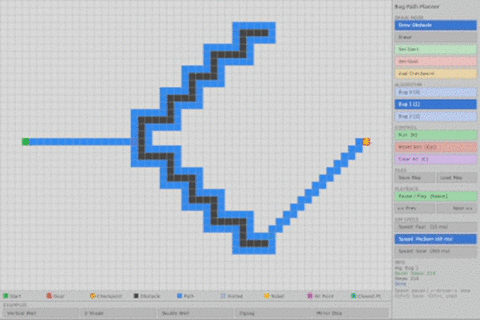
Bug Path Planner : Interactive Navigation Algorithm Visualizer
Interactive visualization tool for Bug0, Bug1, Bug2 reactive navigation algorithms with real-time animation and step-by-step debugging.
About
I am a Robotics M.Eng. student at University of Maryland researching vision-language-action models at GAMMA Lab. With 2+ years of industry experience, I build autonomous systems that perceive, plan, and learn in real-world environments.
My expertise spans perception, motion planning, and hardware deployment across quadrupeds, mobile manipulators, and inspection robots. I work with SLAM, Nav2, embedded systems, and sensor integration across ROS/ROS 2 stacks.
Passionate about bridging classical robotics with learning-based methods. I am seeking a Summer / Fall 2026 internship to drive innovation in autonomous systems and real-world robot deployment.
Contact Me
Brendan Iribe Center, Room 5116
University of Maryland
8125 Paint Branch Dr.
College Park, Maryland 20742, USA