
Overview
Complete ROS 2 mobile robot framework with multi-robot simulation in Gazebo and independent control of differential drive robots.
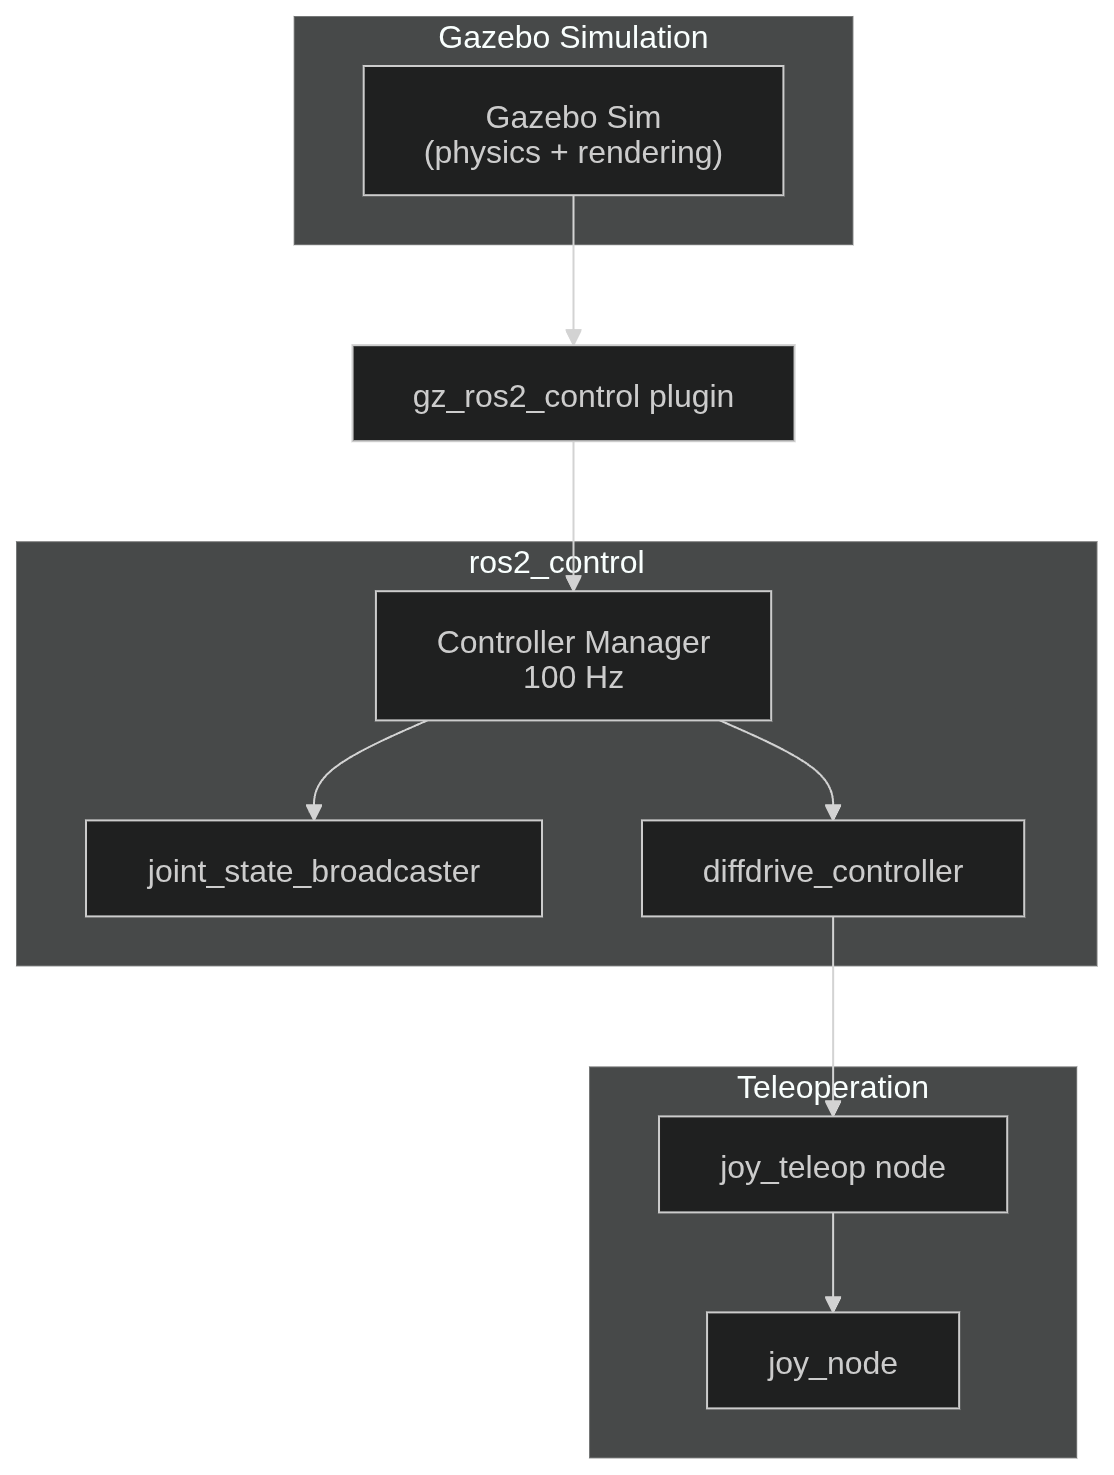
Features
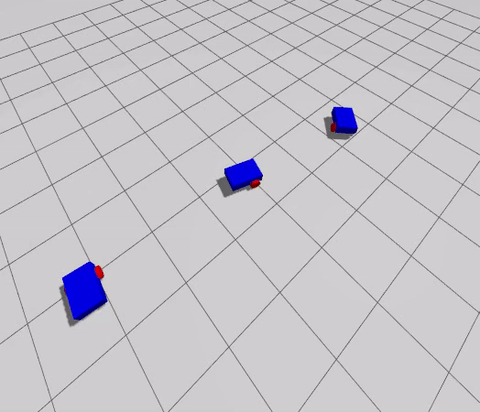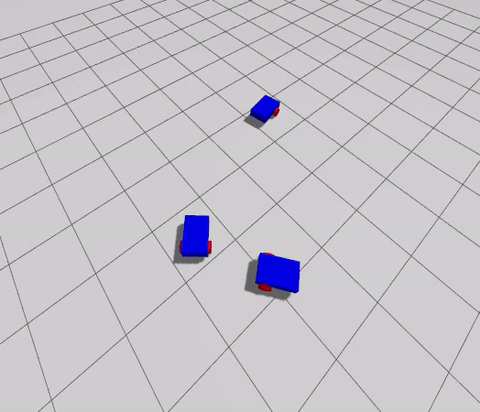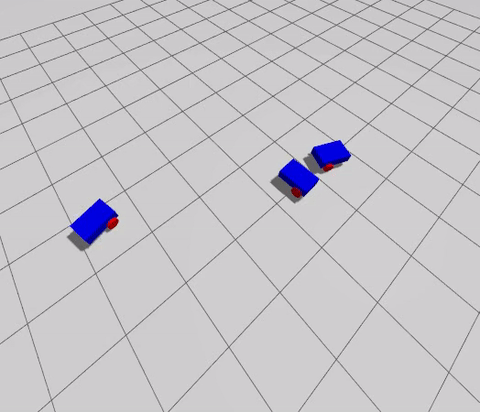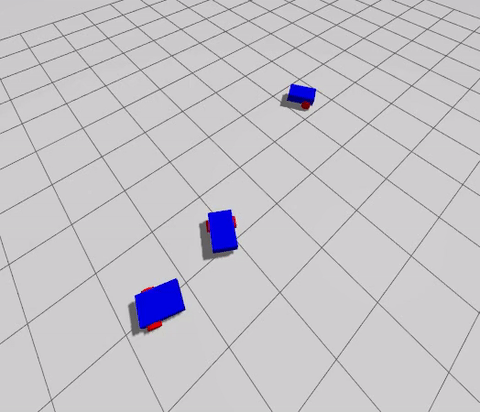
- Multi-robot Support: Spawn and control multiple robots independently
- URDF/Xacro Modeling: Parameterized robot descriptions
- Physics Simulation: Gazebo with accurate collision detection
- ros2_control: Hardware-agnostic control framework
- Teleoperation: Joystick control with deadman switch
- Odometry: Proper TF transformations (odom → base_footprint)
Technical Stack
- Framework: ROS 2
- Simulator: Gazebo Classic
- Control: ros2_control with diff_drive_controller
- Visualization: RViz2
- Speed: 100 Hz control loop
Robot Specifications
- Max Linear Velocity: 0.46 m/s
- Max Angular Velocity: 1.9 rad/s
- Control Rate: 100 Hz
- Multi-robot Tested: Up to 8 robots in single world
Getting Started
git clone https://github.com/svaibhav101/project_zoomlet.git
cd project_zoomlet && colcon build && source install/setup.bash
ros2 launch project_zoomlet multi_robot.launch.py num_robots:=3
Use Cases
- Robot swarm research
- Autonomous navigation testing
- Multi-agent coordination development
- Simulation-to-real validation