
Overview
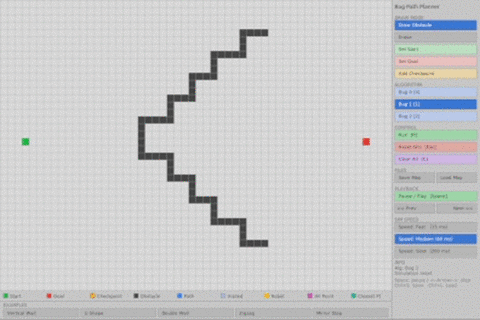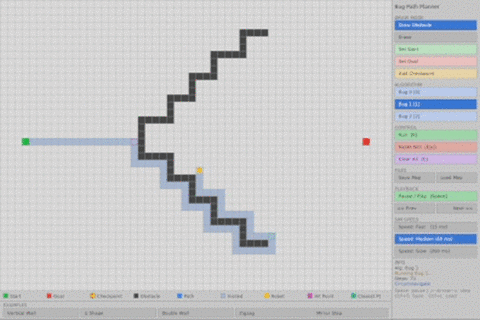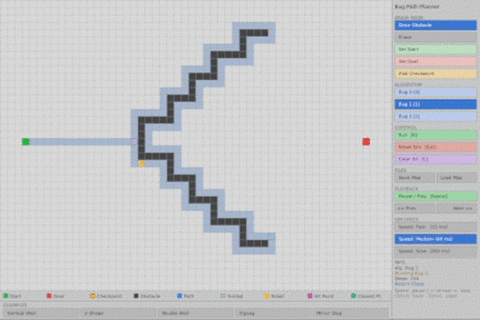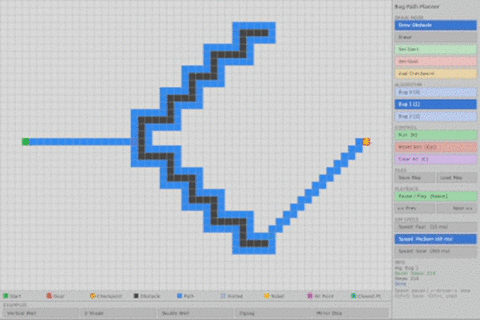
Interactive visualization tool for classical reactive navigation algorithms (Bug0, Bug1, Bug2) with real-time animation and step-by-step debugging.
Features
- Three Algorithms: Bug0 (simple), Bug1 (guaranteed), Bug2 (optimized)
- Real-time Animation: Configurable speed (15-200 ms/tick)
- Interactive Map Editor: Paint obstacles, save/load maps
- Step-through Debugging: Frame-by-frame path analysis
- Performance Comparison: Compare algorithms across 6 environments
Technical Details
- Language: C++
- Graphics: SDL2
- Build: CMake
- Platform: Linux
Getting Started
git clone https://github.com/svaibhav101/bug-nav-cpp-sim.git
cd bug-nav-cpp-sim && mkdir build && cd build
cmake .. && make
./bug_planner
Algorithm Comparison
| Algorithm | Guaranteed | Speed | Best For |
|---|---|---|---|
| Bug0 | No | Fast | Open spaces |
| Bug1 | Yes | Slow | Safe navigation |
| Bug2 | Yes | Fast | Mixed environments |